CYOBot v2 Crawler
The Crawler configuration uses a legged base. Follow its assembly and power instructions before testing movement, and use a clear work area with the robot supported as instructed.
By CYOBot · Updated
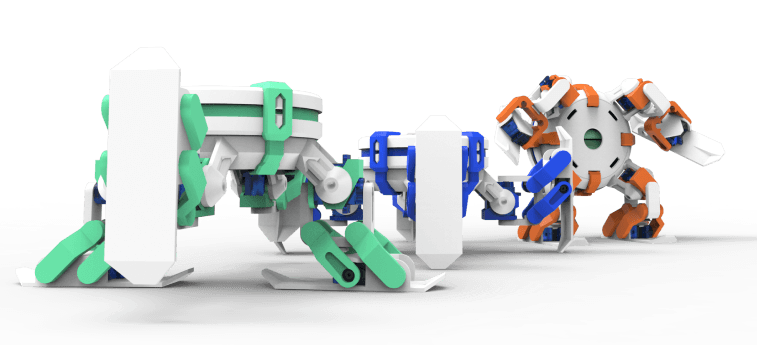
Before you start
The matching CYOBot v2 base and brain, plus the components and power arrangement specified in the official assembly guide.
CYOBot v2 is a modular robotics platform documented in the official hardware repository. That repository describes an ESP32-S3 brain and separates the brain electronics from design-dependent mechanical boards.
Check the actual hardware revision before following a guide. The original CYOCrawler specifications on this website describe the earlier model and must not be treated as v2 specifications. Ask CYOBot about current kit contents, purchasing, availability and support before ordering.
Try a small experiment
- Compare your parts with the matching model's assembly instructions.
- Follow the documented power and connection procedure without substituting another model's wiring.
- Choose the Python or Block guide below and run its baseline example.
- Record the revision, tool and result before attempting a new project.
What to record
Identify the correct assembly and coding guide, establish one working example and plan a small experiment.